We are The BananaBots, a student-driven middle and high school robotics team dedicated to mechanical precision, autonomous computer vision, high-speed control systems, and community STEM empowerment.
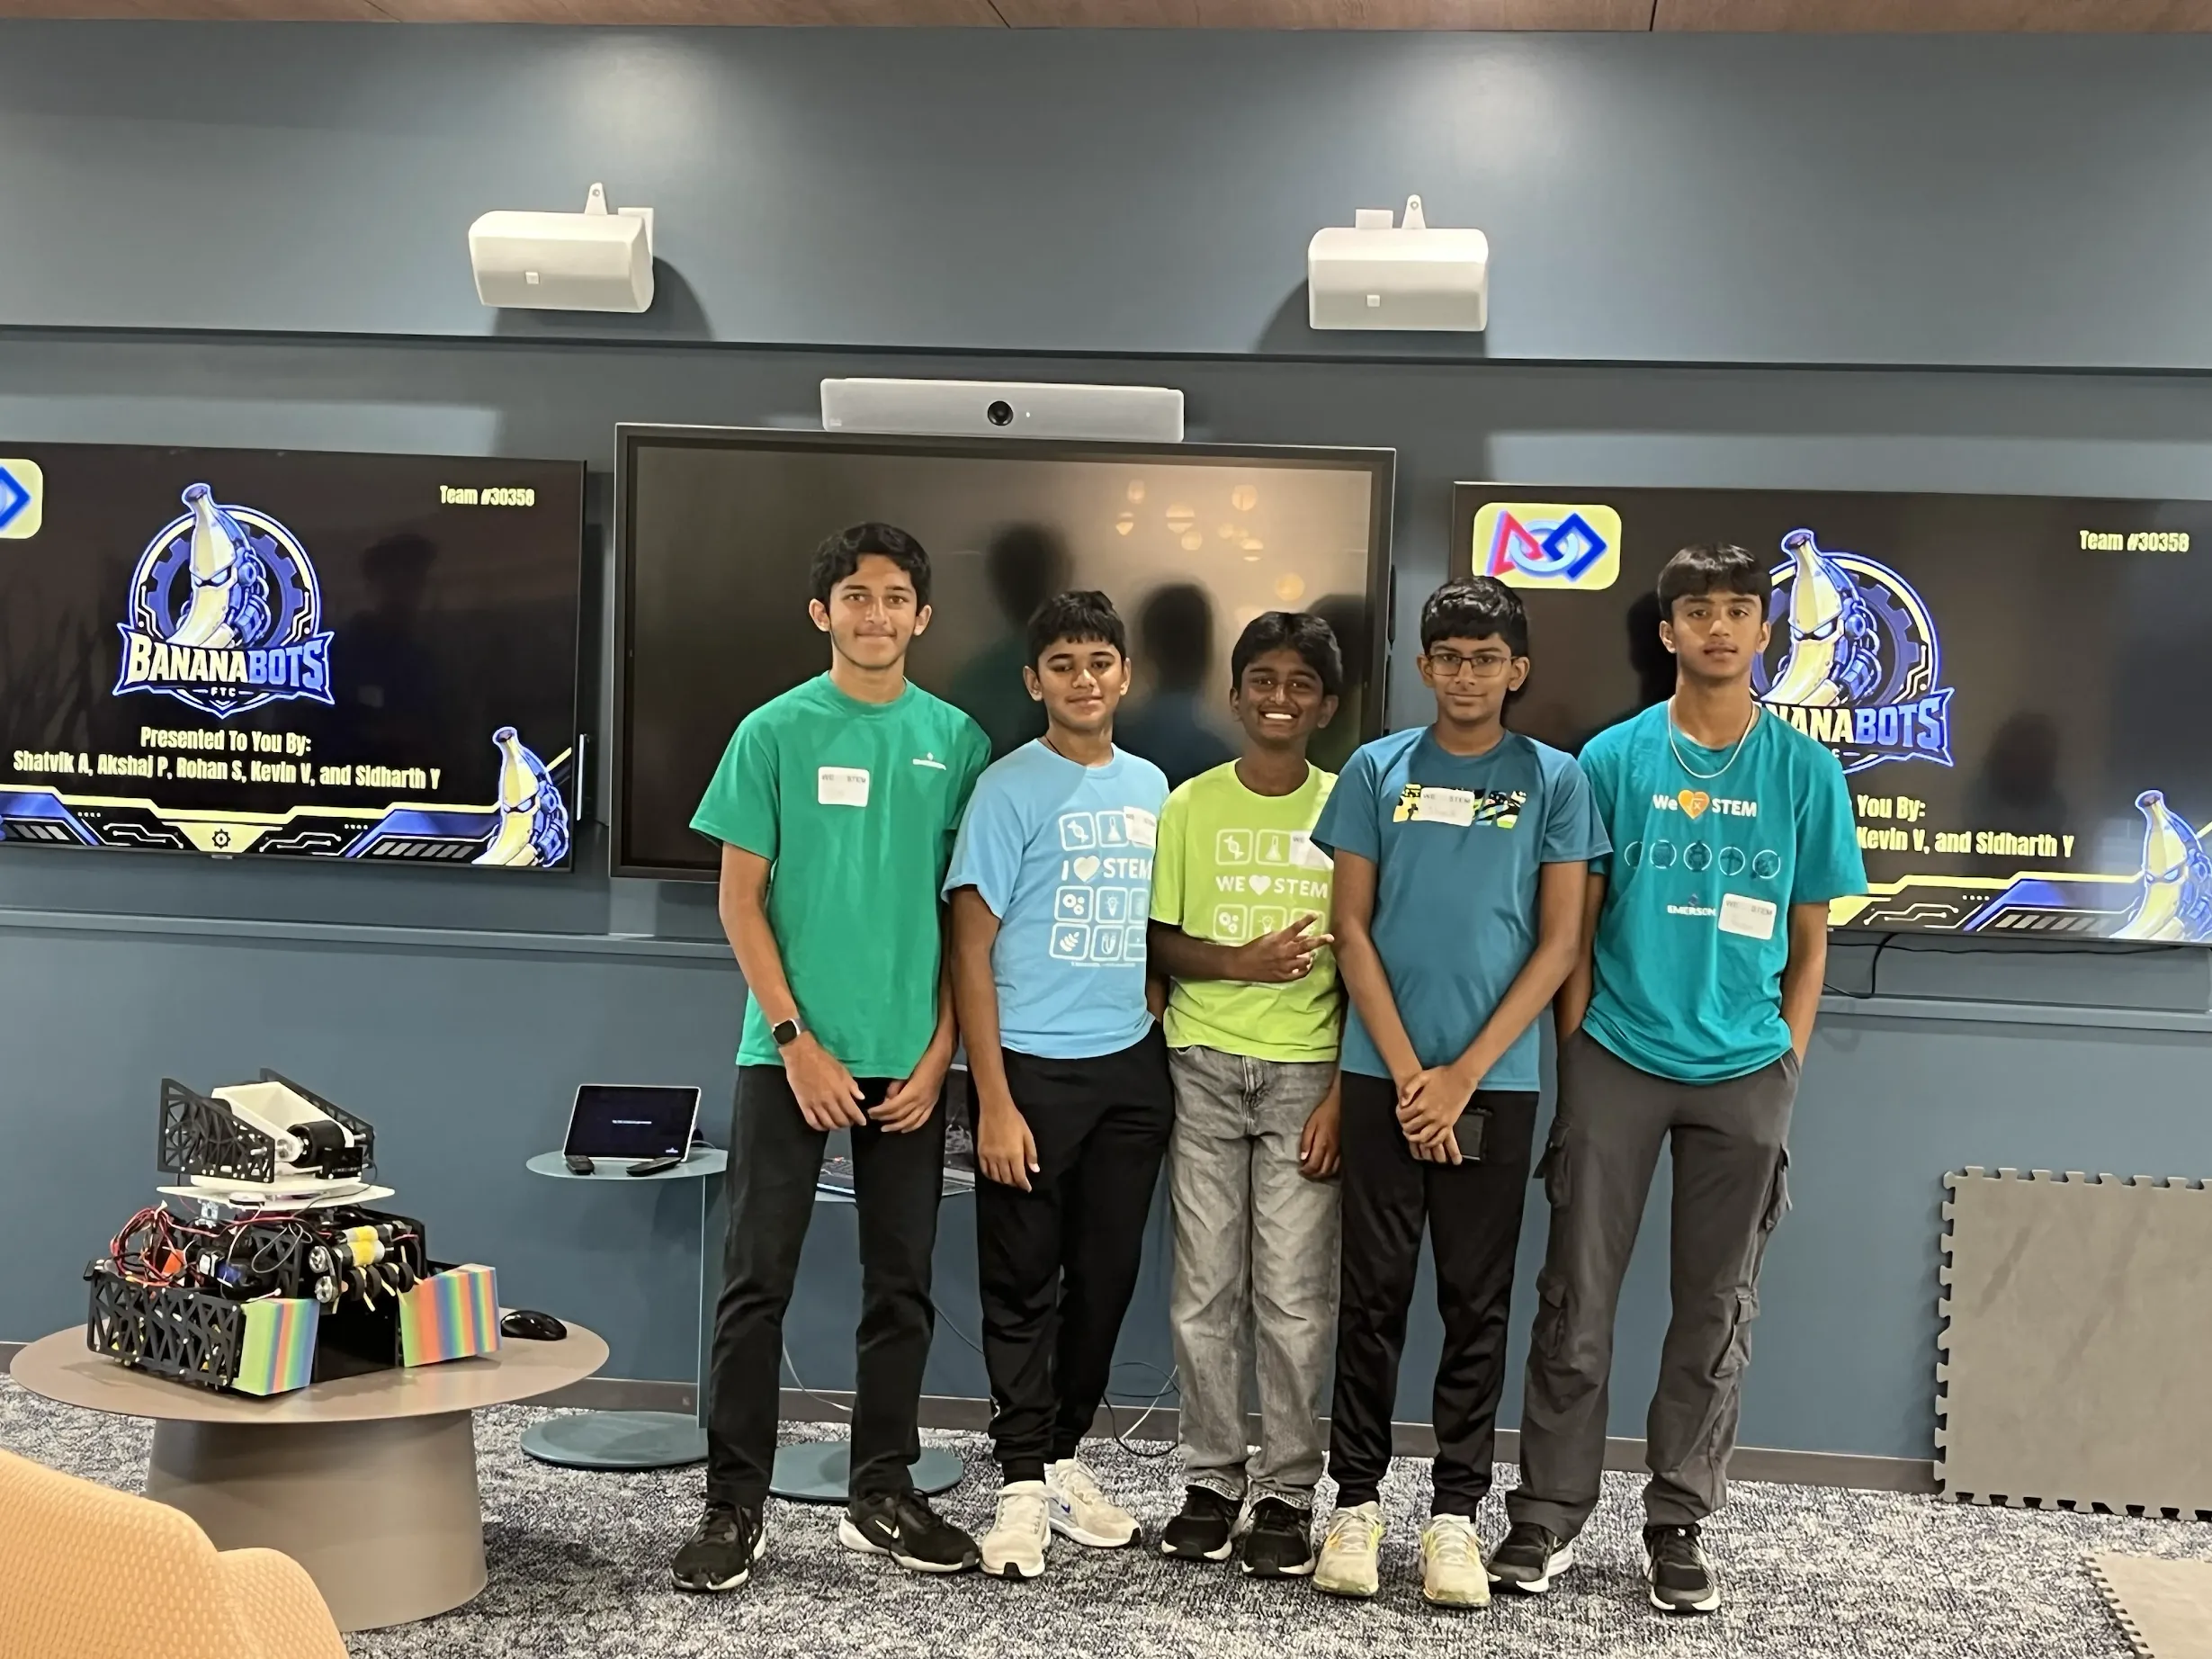
Founded in 2025, The BananaBots bring together passionate middle and high school engineers, programmers, and innovators to compete in the FIRST Tech Challenge while spreading STEM excitement locally and globally.
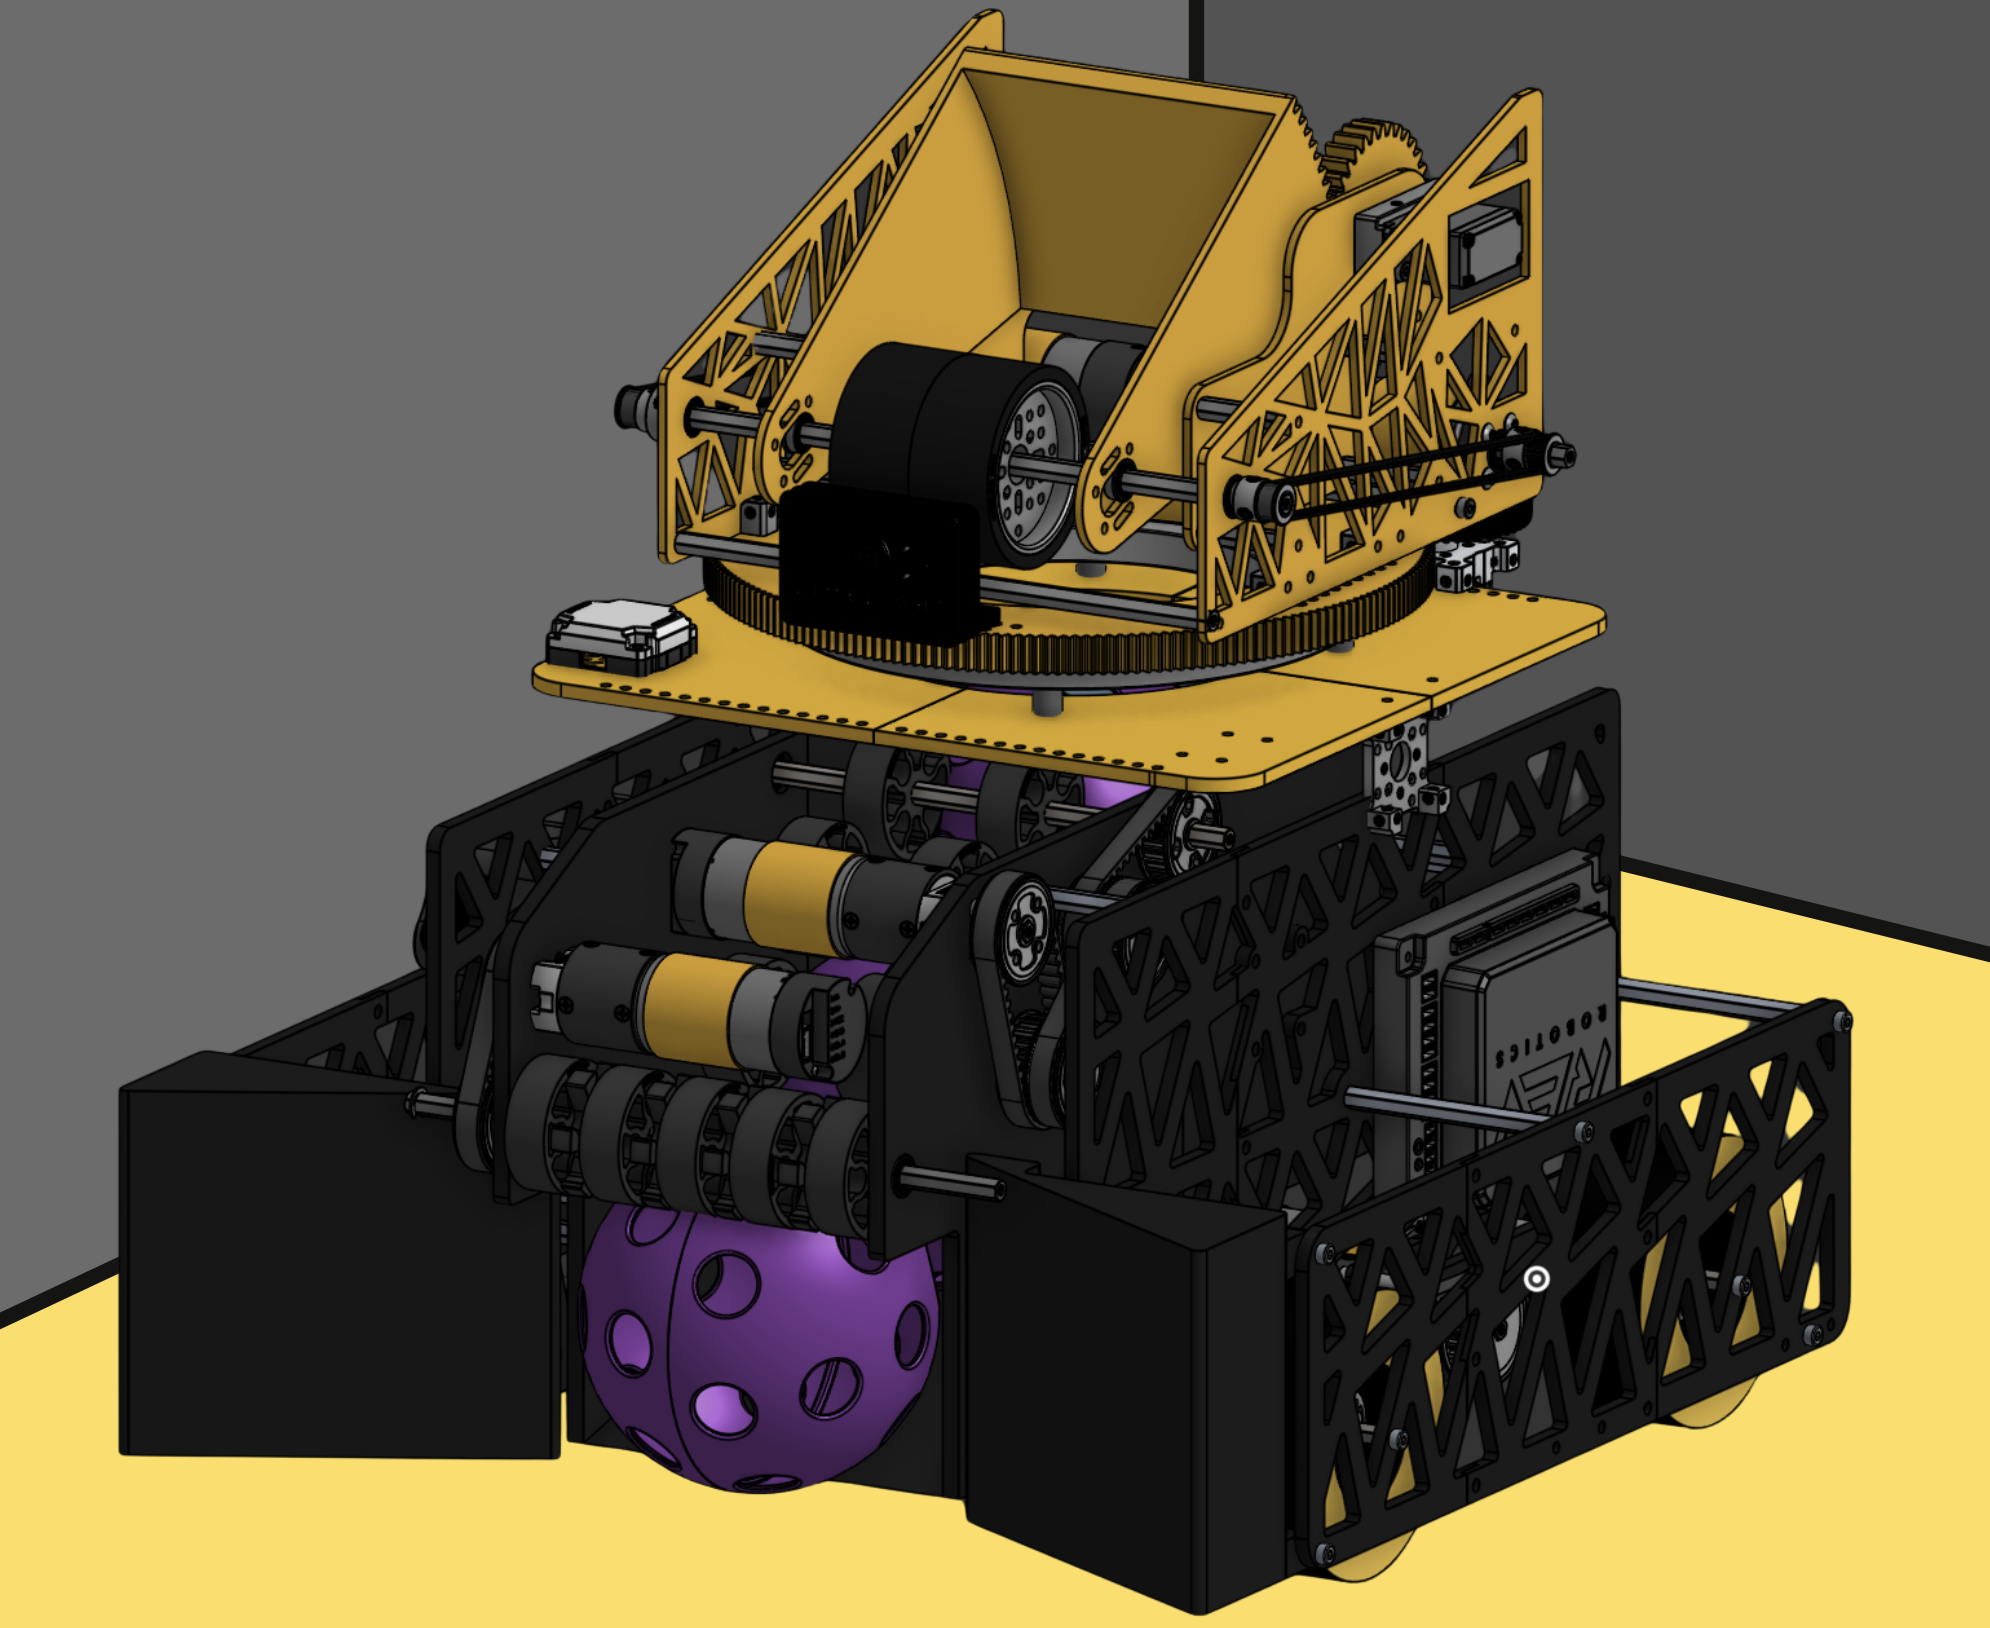
Custom 3D-printed pattern plates and a 360° turret launcher using AprilTags for tracking.
Limelight & OpenCV vision pipelines, AprilTag and odometry for localization, FTC-Dashboard live telemetry, and Pedro Pathing motion profiling.
Fostering teamwork, sharing open-source code repositories and CAD documents, and the supporting STEM community through outreach.
Our flagship 2025-2026 offseason robot engineered for speed, accuracy, and reliability.
Equipped with 4x GoBILDA 435 RPM Yellowjacket motors paired with 104mm mecanum wheels, providing 360° maneuverability with instant acceleration.
Featuring the goBILDA Pinpoint Odometry Computer with 2x 4-bar pods and Limelight 3A vision pipeline for high-precision localization.
public class BananaLimelightAuto extends LinearOpMode {
    private Limelight3A limelight;
    private Follower follower;

    @Override
    public void runOpMode() {
        limelight = hardwareMap.get(Limelight3A.class, "limelight");
        limelight.pipelineSwitch(0);
        limelight.start();

        follower = new Follower(hardwareMap);
        waitForStart();

        LLResult result = limelight.getLatestResult();
        if (result != null && result.isValid()) {
            // Pedro Pathing Bezier Curve Trajectory
            Path scoringPath = new Path(
                new BezierCurve(new Point(startPose), new Point(scorePose))
            );
            follower.followPath(scoringPath);
        }
    }
}Built with strict wire routing standards and high-frequency sensor loops.
Modular state-machine based robot code powered by modern control theory algorithms and real-time visualization.
Recognized for technical excellence, team spirit, and community impact.
League Meet 3
Secured 4th place at League Meet 3 with Geary, demonstrating high-speed scoring and autonomous pathing accuracy.
Season Progress
Preparing for upcoming league meets and championships. Stay tuned for future match results and team updates!
BananaBots is structured into specialized subteams mimicking professional engineering firms.
Designs 3D models in Onshape, operates CNC mills, 3D printers, and assembles robust mechanical drive systems.
Onshape • 3D Printing • MachiningDevelops Java control software, autonomous vision pipelines, PID tuning, and telemetry diagnostics.
Java • Limelight • Pedro PathingManages team finances, sponsorship acquisition, web development, social media, FLL team mentorship, and community STEM events.
Sponsorships • Web Dev • FLL Mentorship • Demos
Building a competitive robot requires parts, tools, registration fees, and travel. Partner with us to empower young innovators and showcase your brand!
Curated FTC documentation, software libraries, team repositories, CAD files, learning tools, and official FIRST portals all in one place.
Access our open-source autonomous & teleop codebase, Pedro Pathing configs, and libraries.
Watch match recordings, robot reveal videos, autonomous testing clips, and CAD walkthroughs.
Join our community server for technical discussions, strategy sharing, and outreach events.
Follow our build season behind-the-scenes, competition updates, and outreach photos.
3D CAD design software, tutorials, official team models, and drivetrain guides.
Beginner-friendly video playlist tutorial demonstrating CAD modeling step-by-step.
Official 3D Onshape CAD document and assembly for BananaBots robot design.
Video tutorial guiding how to design and assemble a basic FTC robot drivetrain in CAD.
Interactive Canva presentation covering CAD design fundamentals and team standards.
FTC SDK, team codebase repositories, and Java programming tutorials.
Official FIRST Tech Challenge Robot Controller repository for Android Studio Java development.
Primary GitHub repository for BananaBots FTC robot controller, autonomous programs, and teleop code.
Beginner-friendly video guide explaining basic Java programming for robotics.
Whether you are a student looking to join the team, an engineer wanting to mentor, or a sponsor interested in supporting STEM education, we'd love to connect with you!
Austin, Texas